- Present
Research Intern, JingDong Future Academy
Beijing, China · Embodied AI, world-action models, and world models.
Mentor: Dr. Jun Cen
I am a research intern at JingDong Future Academy, mentored by Dr. Jun Cen, working on embodied AI, world-action models, and world models. Previously, I was a research intern at BAAI, mentored by Prof. Shanghang Zhang, and a research assistant at Hamad Bin Khalifa University, supervised by Dr. Zhihe Lu.
I received my M.E. and B.E. in Electronic Information Engineering from Guangdong University of Technology in 2025 and 2022, respectively, under the supervision of Prof. Jing Chen.
My research interests include embodied AI, world-action models, vision-language-action models, tactile manipulation, and efficient robot learning.
Beijing, China · Embodied AI, world-action models, and world models.
Mentor: Dr. Jun Cen
Beijing, China · Vision-language-action and world-action models.
Mentor: Prof. Shanghang Zhang
Doha, Qatar
Supervisor: Dr. Zhihe Lu
Shenzhen, China · Computer Science
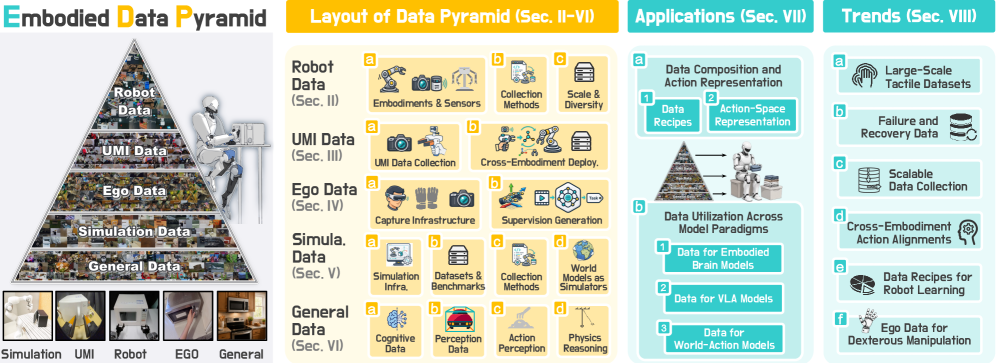
arXiv preprint arXiv:2607.24744, 2026
A data-centric survey that organizes embodied manipulation data into a five-level pyramid and connects heterogeneous data recipes to embodied foundation models and open research challenges.
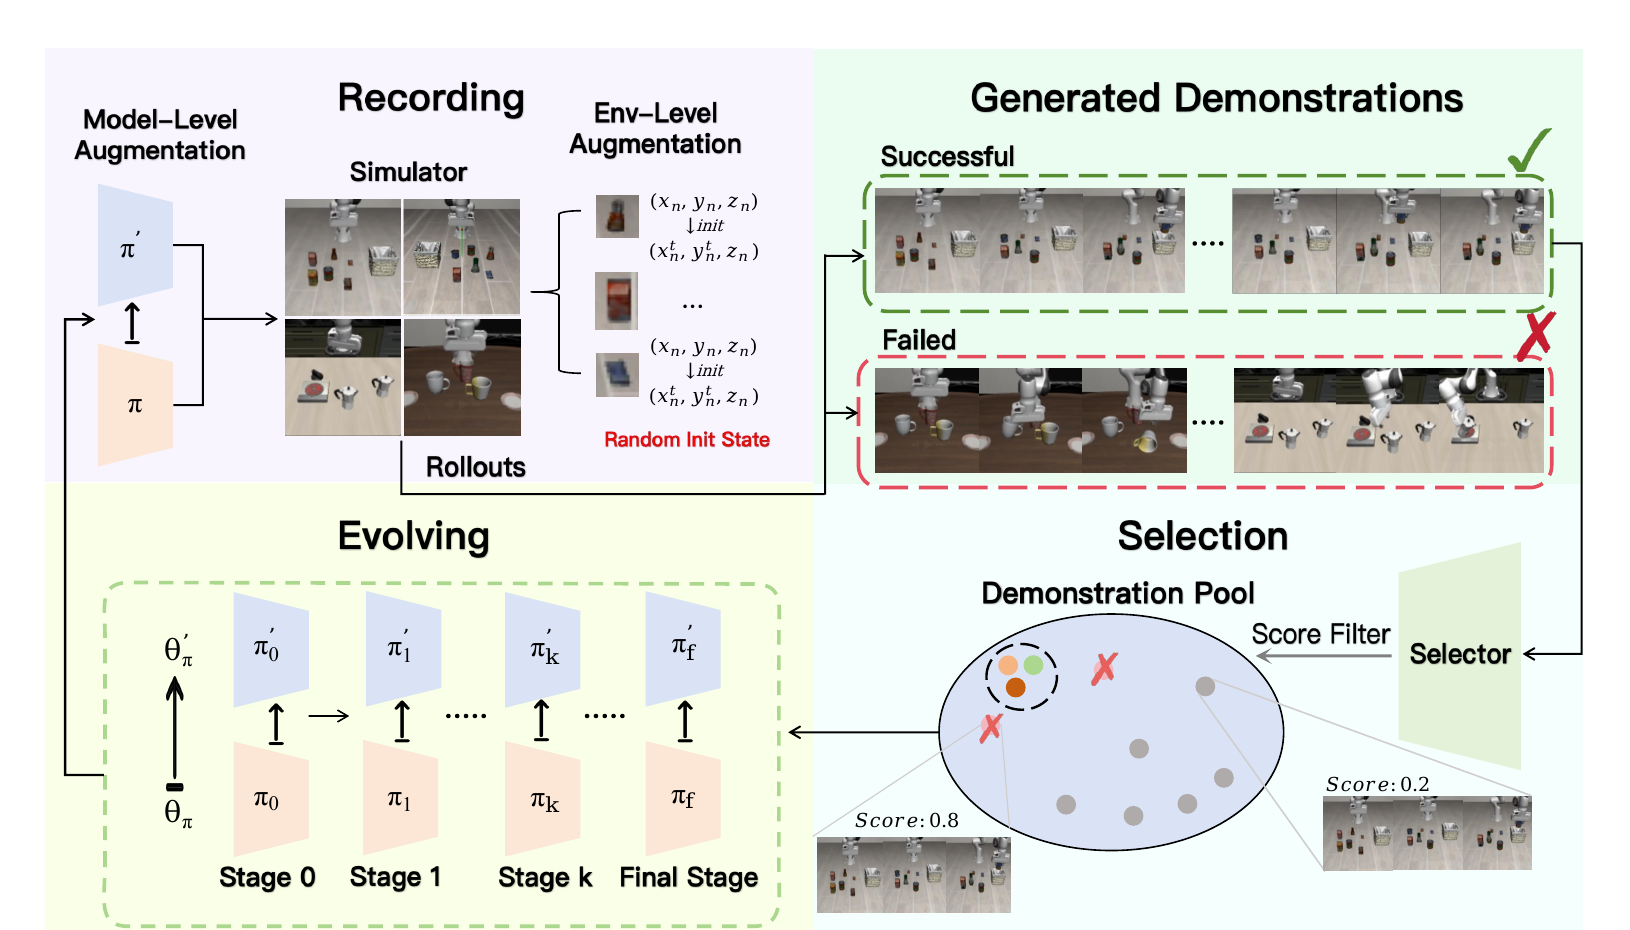
IEEE Robotics and Automation Letters (RA-L), 2026
SEIL enables few-shot policies to improve through simulator rollouts, dual-level augmentation, and informative-trajectory selection.
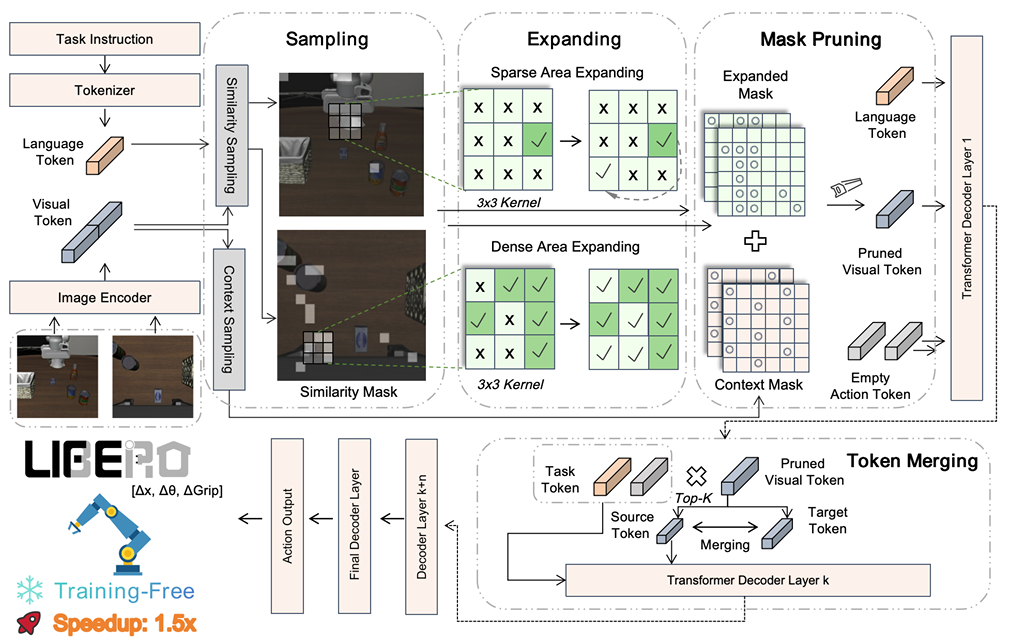
IEEE Robotics and Automation Letters (RA-L), 2026
TEAM-VLA accelerates VLA inference without retraining by expanding informative tokens and merging redundant ones under action-aware guidance.
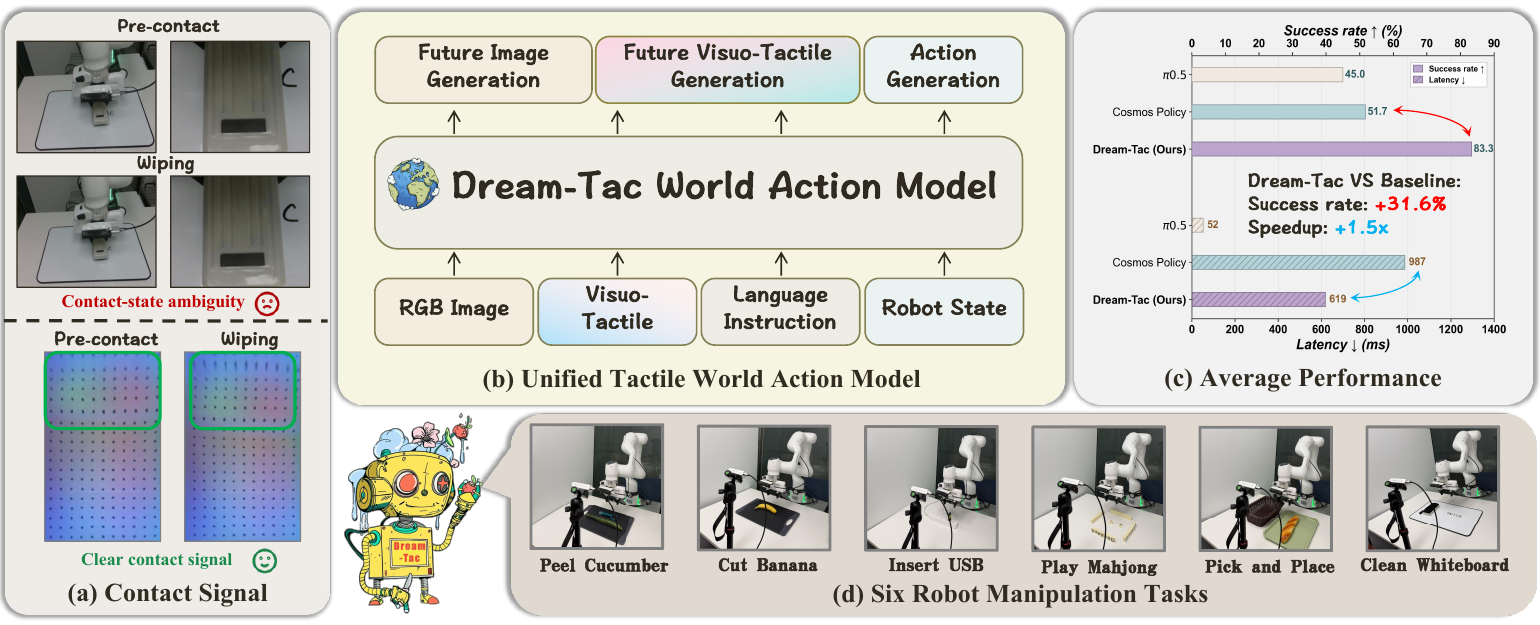
ACM Multimedia, 2026
Dream-Tac jointly models actions, future vision, and tactile dynamics for contact-rich manipulation through contact-aware fusion and efficient inference.
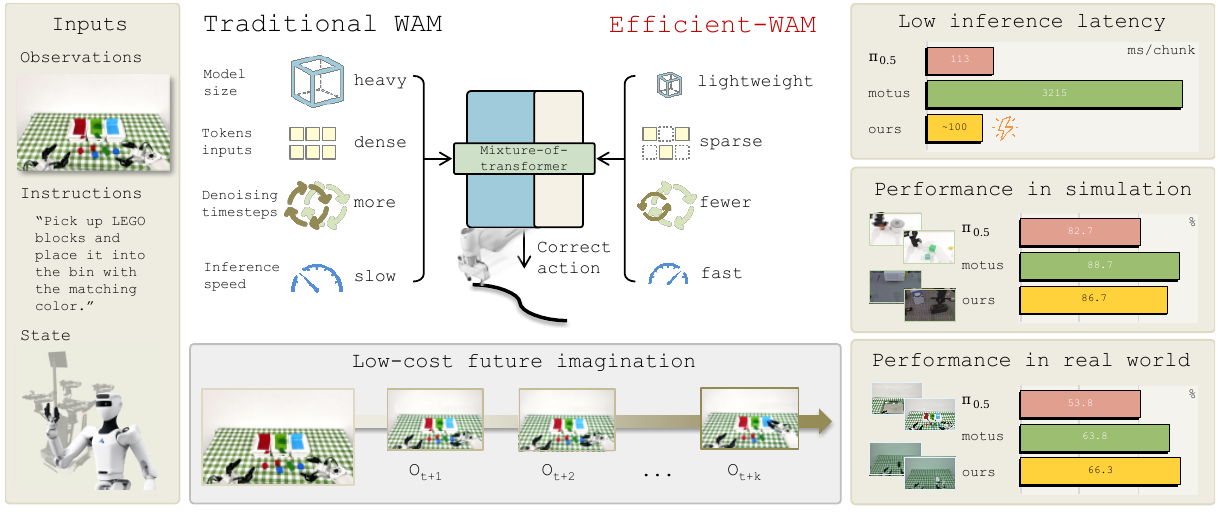
Technical Report, 2026
Efficient-WAM combines a compact video expert, sparse future latents, and asymmetric denoising to reduce the cost of future imagination.
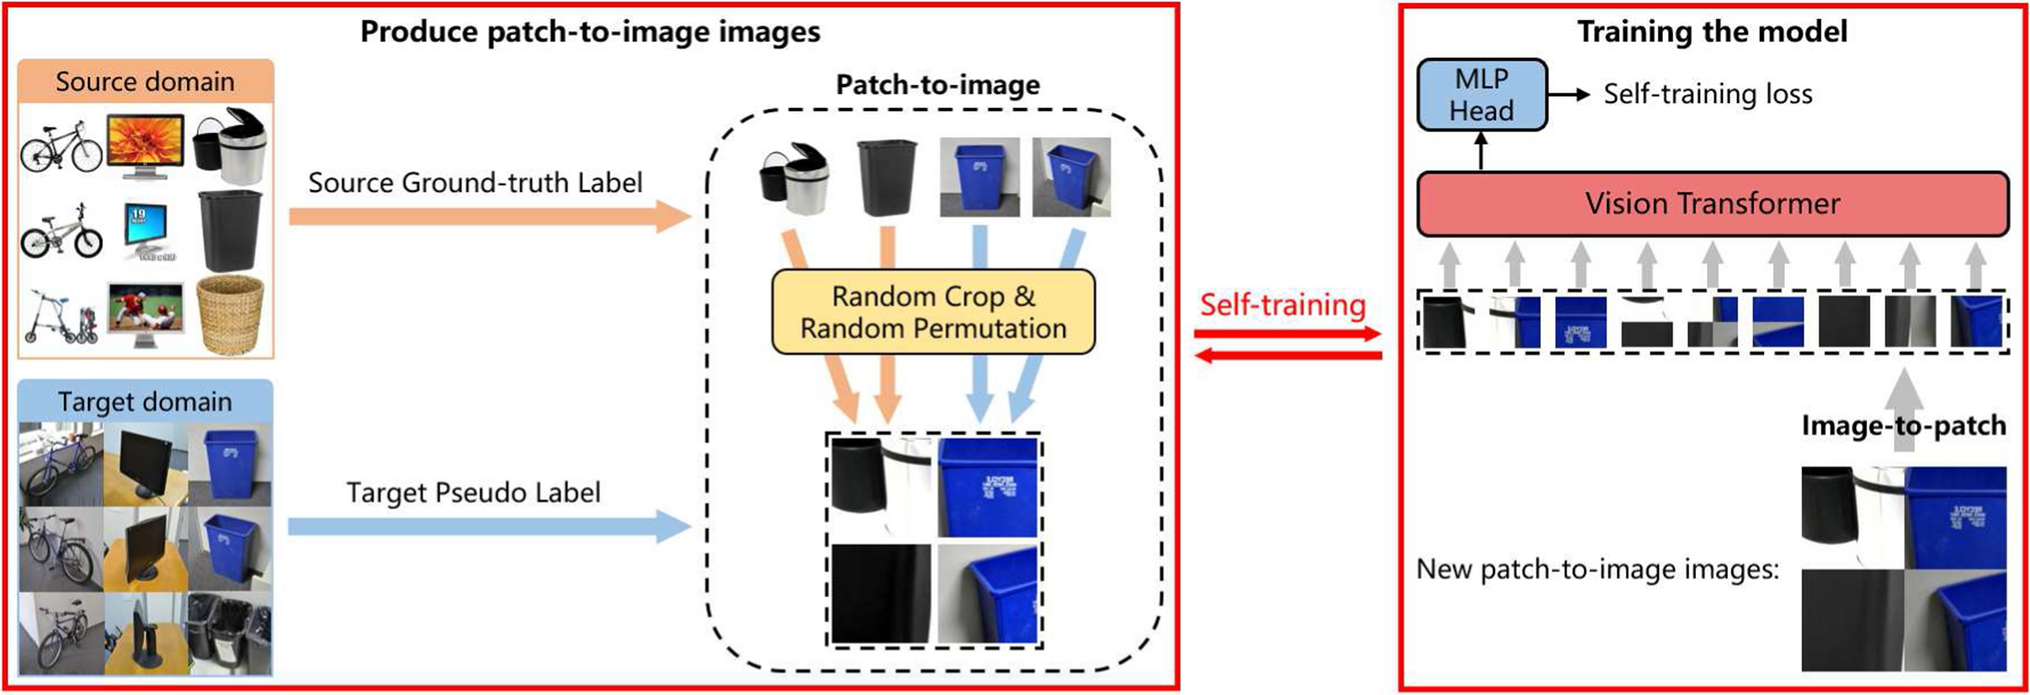
Neural Computing and Applications, 2023
A self-training UDA method combining cross-domain patch aggregation with centroid-alignment loss for vision Transformers.
* Equal contribution. † Project leader. ‡ Corresponding author.